Curation Metrics Are a Post-Training Decision: Auditing Trajectory Smoothness for Adapting Robot Foundation Models
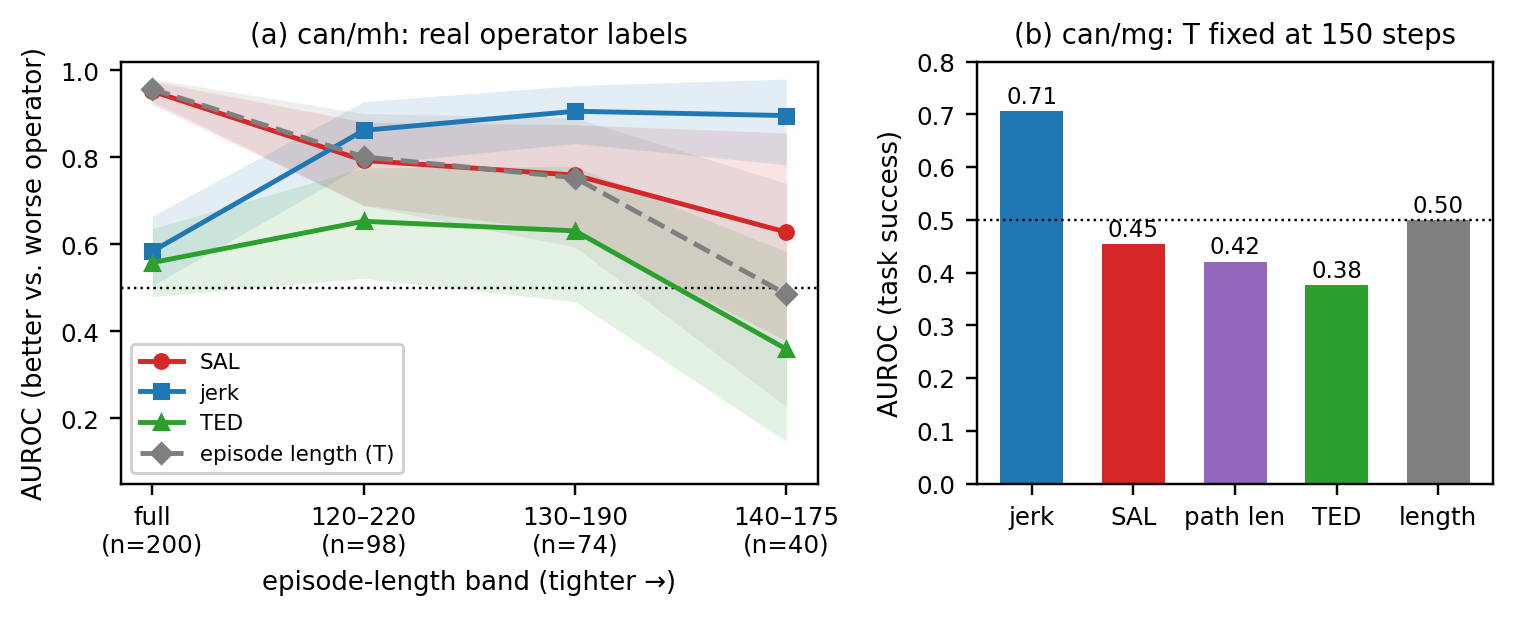
Shows that published smoothness metrics for curating robomimic demonstrations mostly track episode length and operator skill rather than task success; curating by the contact-aware TED metric cut downstream policy success by a third versus random selection. Accepted as a poster at the NeurIPS 2026 RoboPAD workshop. It builds on the base preprint, “Smoothness Ranks Skill, Not Success: An Audit of Published Trajectory-Smoothness Curation Metrics Under Episode-Length Controls” (arXiv:2610.17427).